(C:)
 Design
 Red Bull racing
 Racing drone
 Simple Irrigation System
 Rick & Morty Portal Gun
 USO
 Spidy
 FAJA
 SOCIUS

USO - Hexapod Robotic Spider
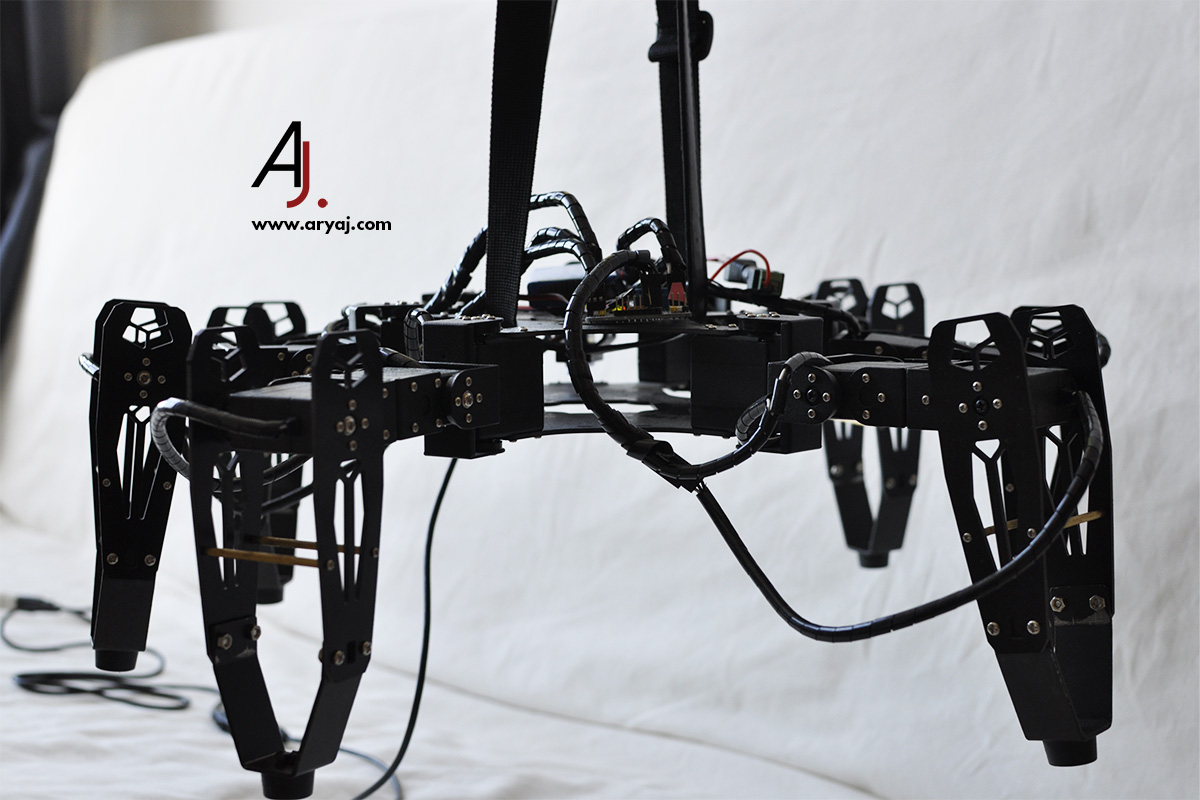
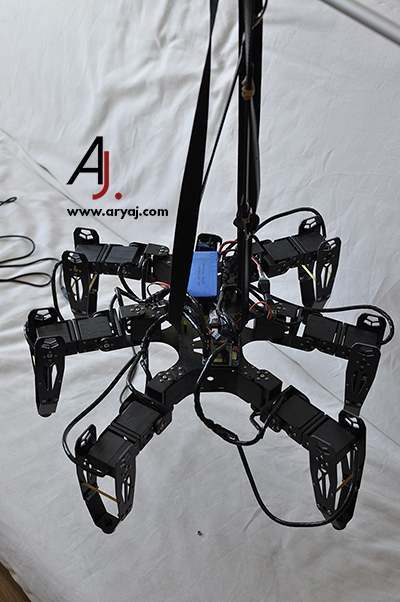
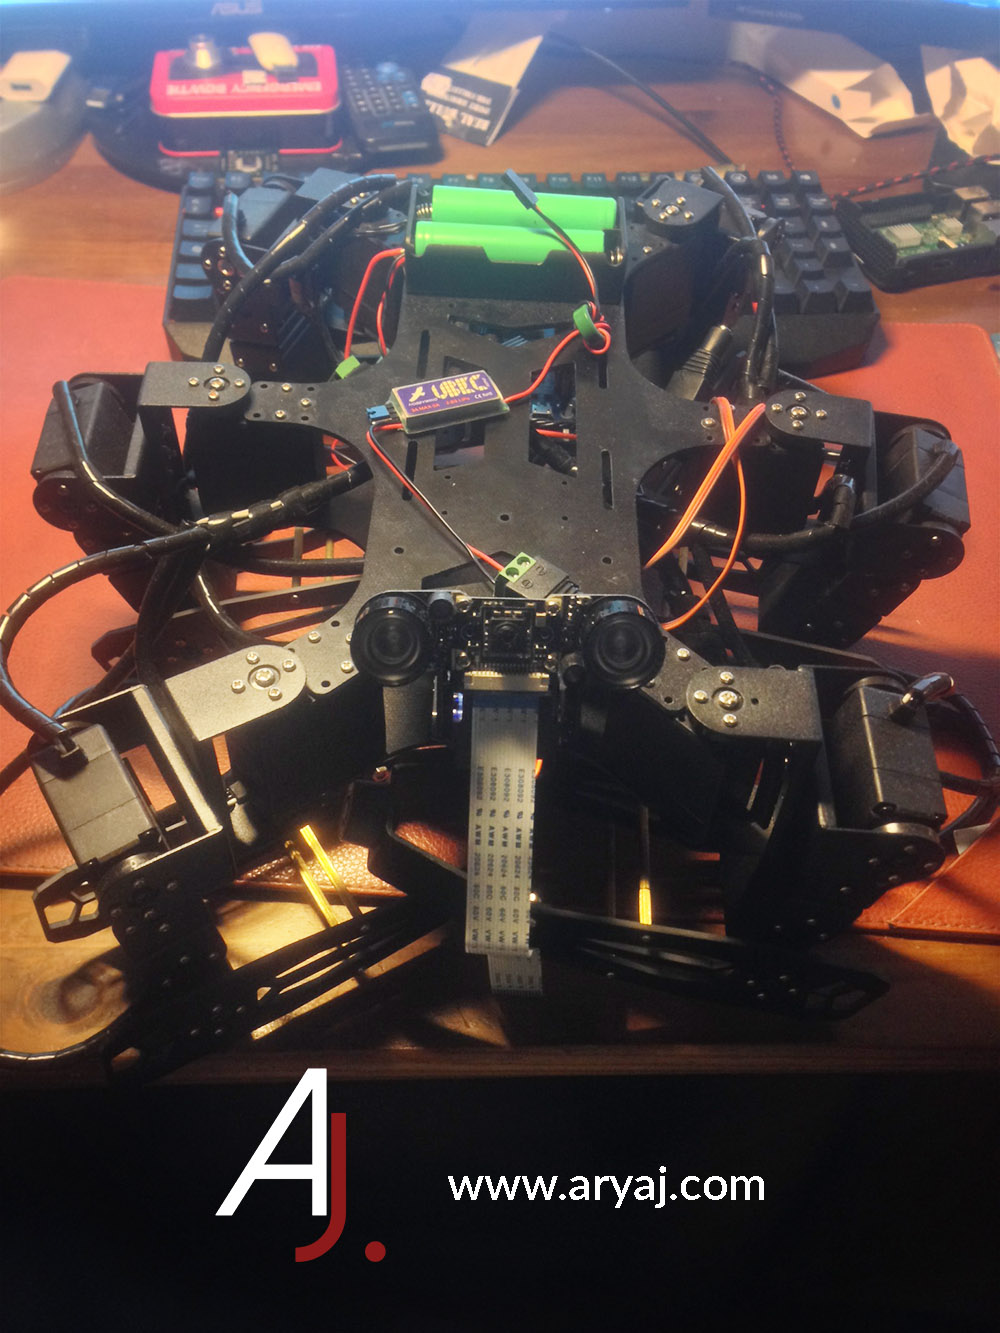
I wanted to challenge myself and program a hexapod robot from scratch. I find it cool and interesting to do it on my own. I knew that implementing the control of 18 motors simultaneously would be hard and I wanted to see if I was able to do it.
The hexapod robot can walk on uneven surfaces and remains stable. I included a pan and tilt support for the camera and a live stream to a ground station.
This was programmed in C++ only.